SciEdu_steps_20261119_relabel_100k_pi05
robot arm control policy for educational experiments
467 posts
robot arm control policy for educational experiments
Trained using the ACT method (Action Chunking with Transformers — an imitation learning method that predicts short chunks of actions instead of single steps), this model is built for the so-called so_follower robotic arm and designed to handle object manipulation tasks such as picking up cubes and…
Developed by Amazon-FAR, this model is designed for bimanual robot manipulation and real-time dynamics prediction using teleoperation data. It includes dynamics checkpoints, an image tokenizer, and test scenes.
fine-tuned model for robotic arm control
This model is an intermediate 10k-step checkpoint from the coarse-vla project, fine-tuned on top of lerobot/pi05_base. It controls a UR10e manipulator equipped with a Robotiq 2F-85 gripper to precisely insert four shaped pegs into a board within the MuJoCo simulator.
NeyroLearn
@neyrolearn
New models from Hugging Face every morning: video, images, LoRAs and LLMs with examples and links.
Most liked on Hugging Face this week
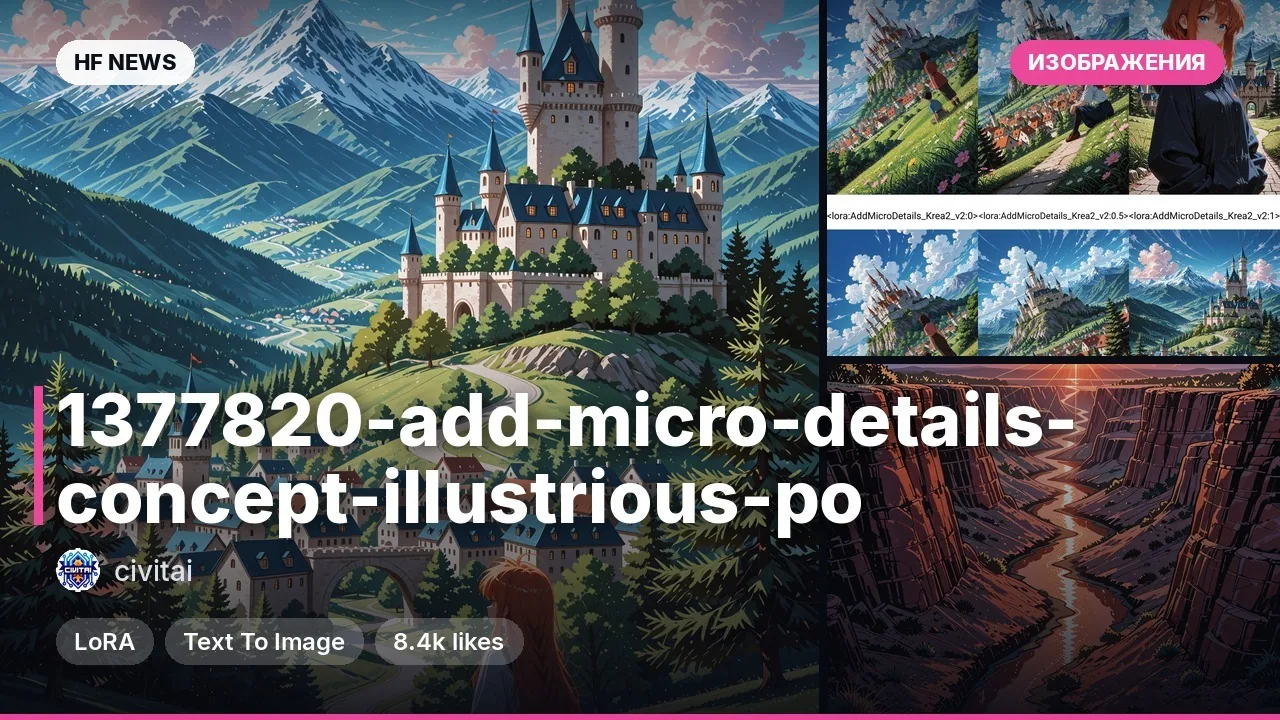
Images · 8.4K
 18+
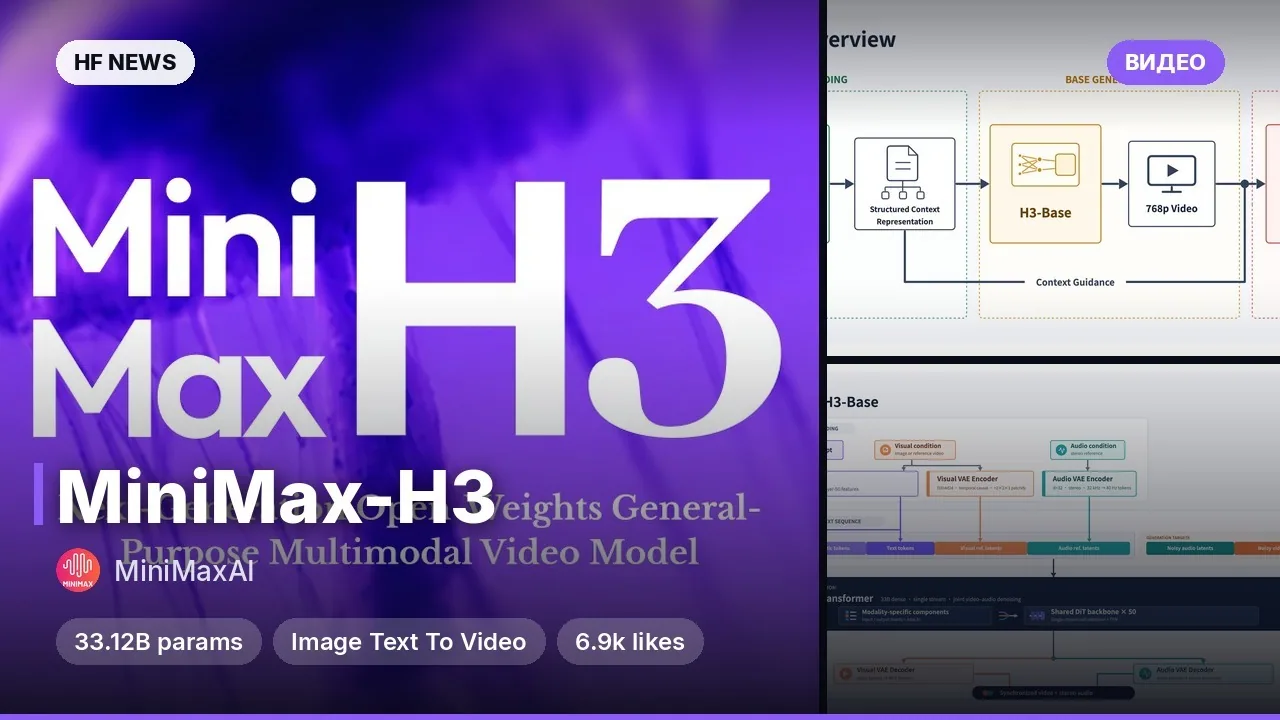
Video · 7.2K
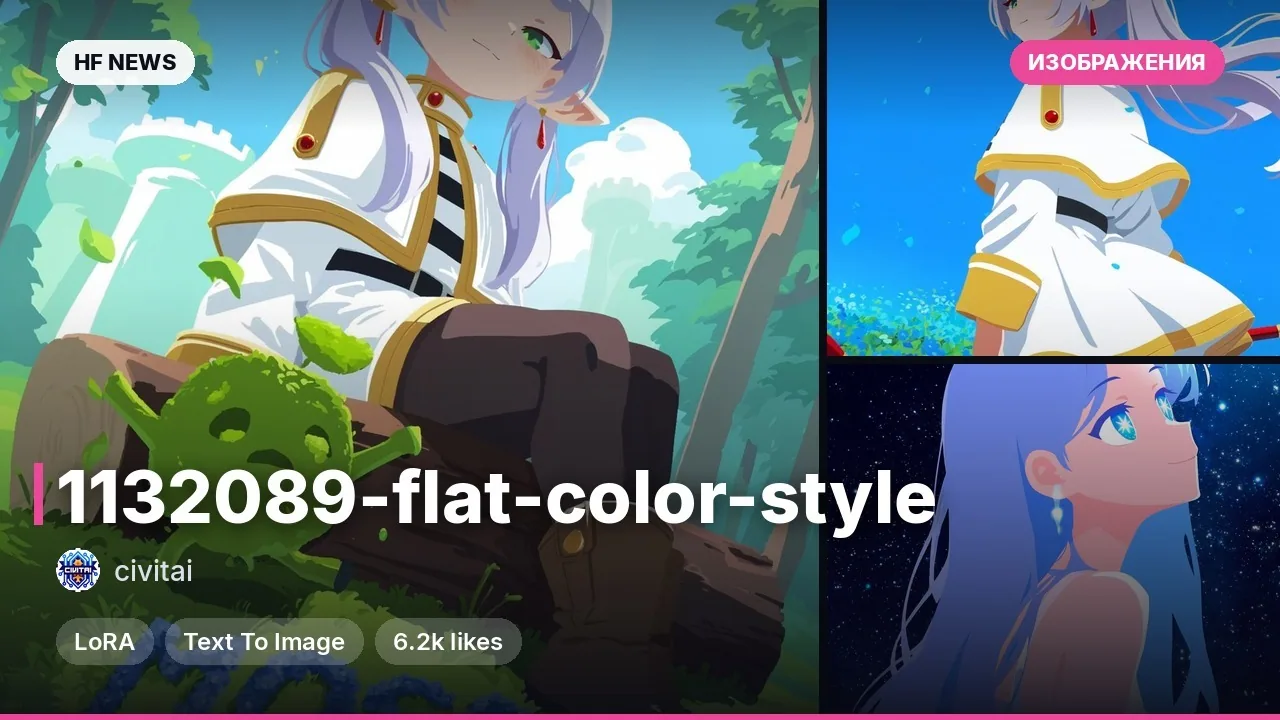
Images · 6.2K
Computer vision · 3.5K
Images · 3.1K
 18+