chomeed/task2_full_grc_subtask_rel_chunk30_bs128_1120_40k
a pi0.5 model checkpoint for the robotic cable insertion task
Section
Fresh policies and models for controlling robots.
a pi0.5 model checkpoint for the robotic cable insertion task
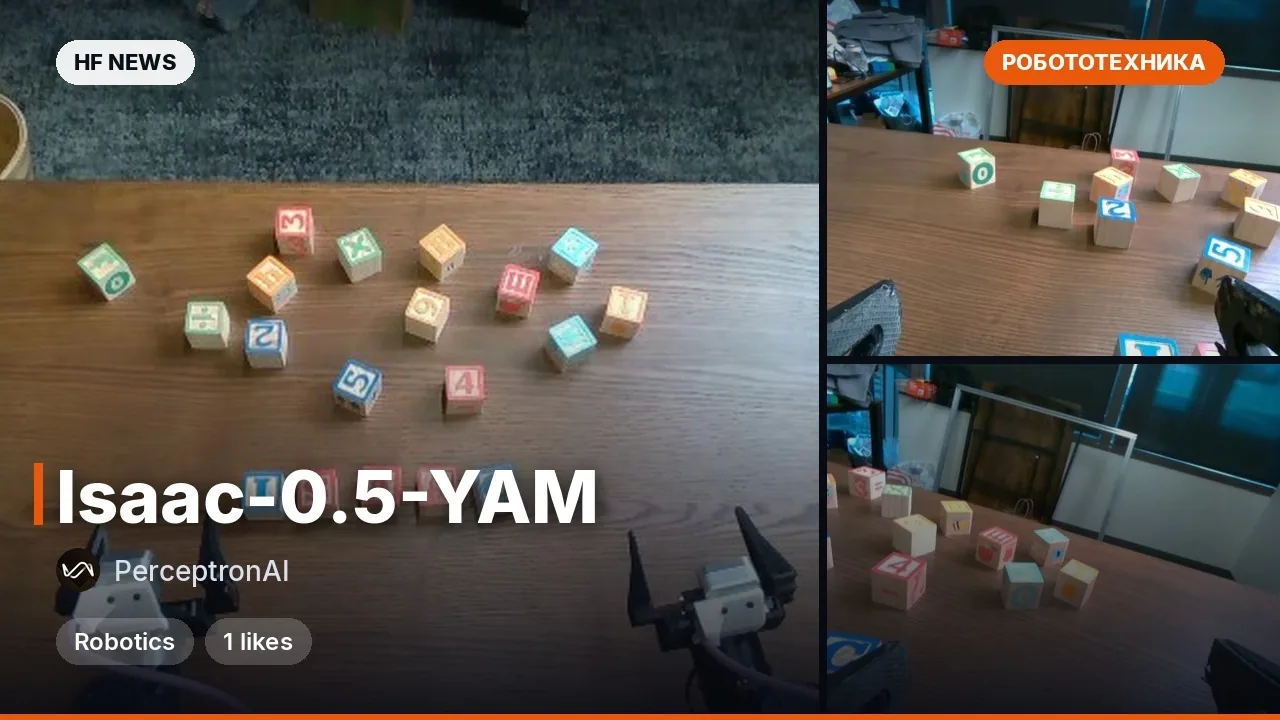
This model is a trained robotics policy checkpoint created using the Linear Decodability Supervision method at step 1469. It was trained on all available localization scenes and is designed to work with the native InternW0-Delta LIBERO runtime.
robot arm control policy for educational experiments
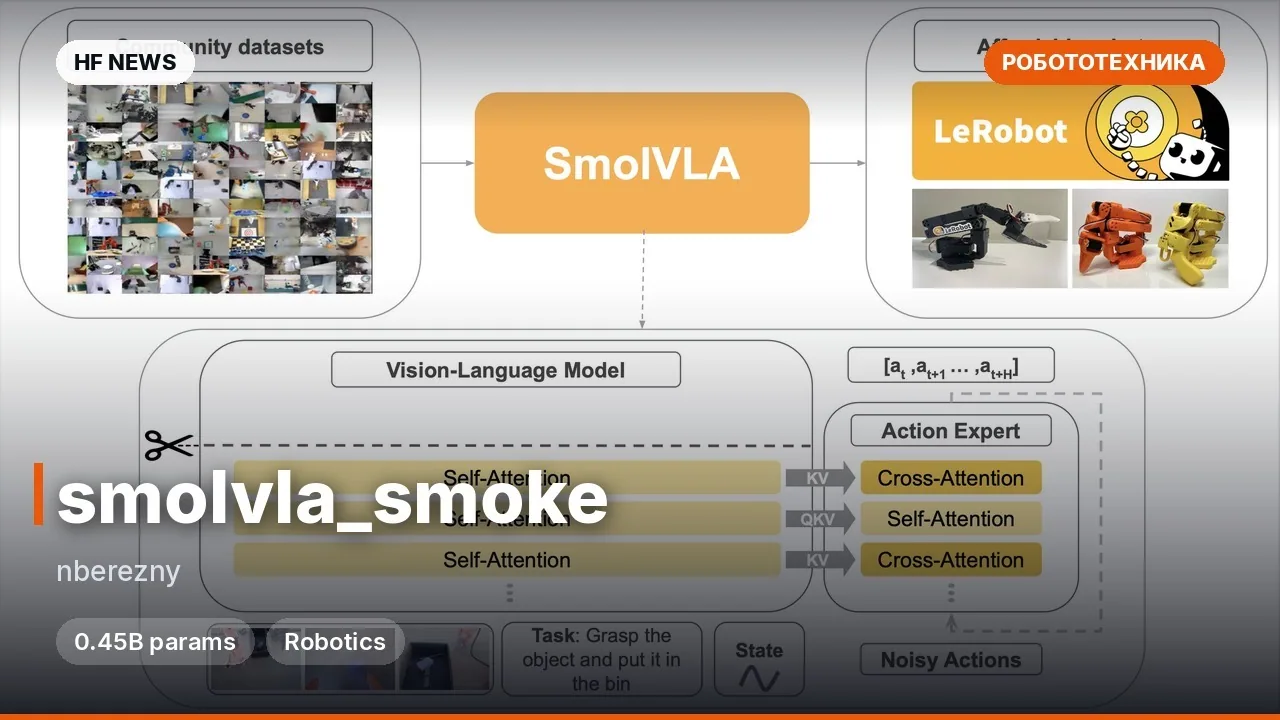
Trained using the ACT method (Action Chunking with Transformers — an imitation learning method that predicts short chunks of actions instead of single steps), this model is built for the so-called so_follower robotic arm and designed to handle object manipulation tasks such as picking up cubes and…
NeyroLearn
@neyrolearn
New models from Hugging Face every morning: video, images, LoRAs and LLMs with examples and links.
Most liked on Hugging Face this week
Images · 8.4K
 18+
Video · 7.2K
Images · 6.2K
Computer vision · 3.5K
Images · 3.1K
 18+