TAPTIC/groot17_taptic_all_b8_200k
multi-task robot arm checkpoint
2 min readupdated
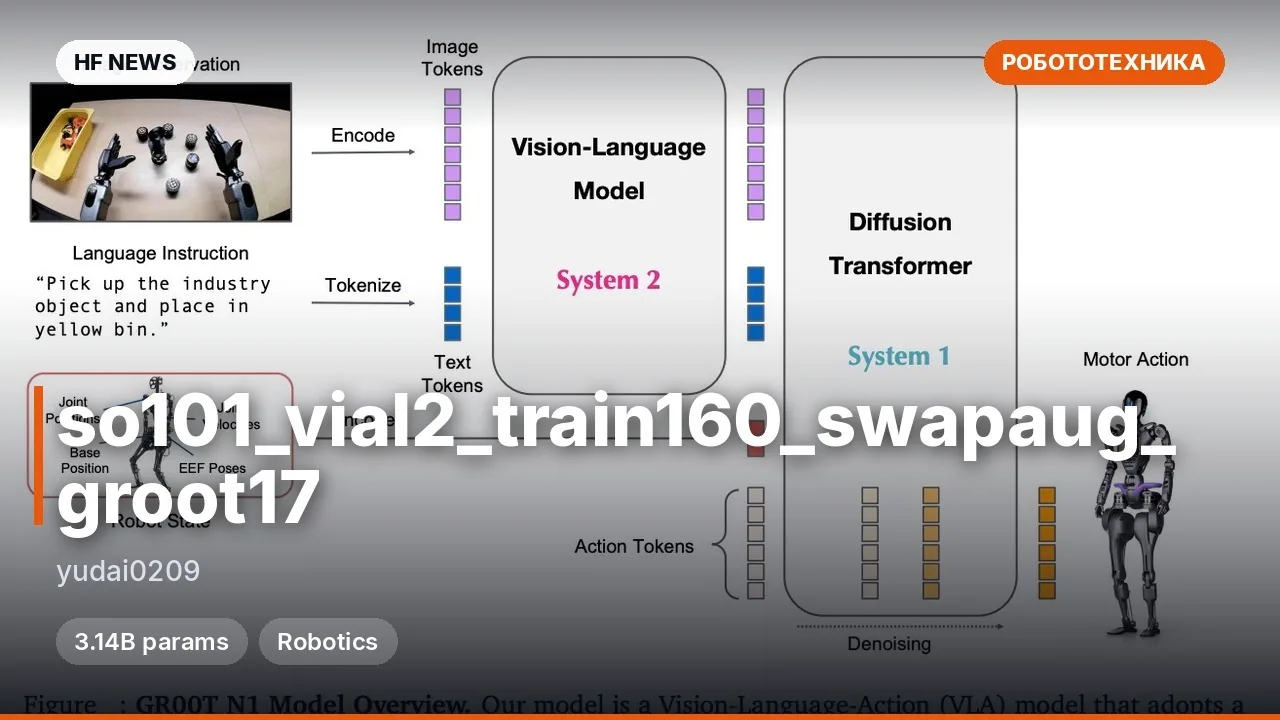
This intermediate checkpoint (100,000 steps) controls a robotic arm and manipulator built on the NVIDIA GR00T-N1.7 architecture (3B parameters). Trained with the LeRobot library, it handles 13 everyday manipulation tasks, including object handling, opening bottles, and precise finger movements. The checkpoint targets robotics researchers and developers working with matching hardware (Panda and XHand) who want to test and improve autonomous arm behavior using open validation results.
Key features
- Multi-task training: tuned across 13 different tasks (912 episodes).
- Hardware support: coordinates Panda joints alongside the 12 joints of an XHand dexterous hand.
- Validation: evaluated on held-out data with measured positioning and rotation errors.
- Trained on LeRobot: built using the LeRobot library and default settings with a batch size of 8.
What you can do
- Test the checkpoint: benchmark the model's current performance on your own robotics testbed.
- Continue training: use the weights for fine-tuning on new tasks or custom datasets.
- Analyze metrics: compare positioning accuracy and joint errors against your own baselines.
Example
Load the model via the LeRobot library for inference or validation on open robot arm episodes.
Read more
Details• Base: nvidia/GR00T-N1.7-3B (3B parameters, LeRobot library)
• Data: 13 tasks, 912 episodes, 336,658 frames (10 fps)
• Validation metrics (overall): position 43.51 mm, rotation 8.49°, hand 6.31°
• Training: batch size 8, 200k steps planned, cosine LR, bf16, seed 42


Comments